In my last year of highschool, I ended being the lead for our robotics team, starting it back up again after a long break since before COVID (and my time at the high school)! We took part in the general robotics section of the SkillsOntario competition (not the vex robotics competition!!), and ended up placing 5th in the finals! From the fall when the club started to winter break, not much work got done, we were more focused on having too much fun yapping at meetings instead of working. After the winter break, we all put in more effort into getting work done on time.
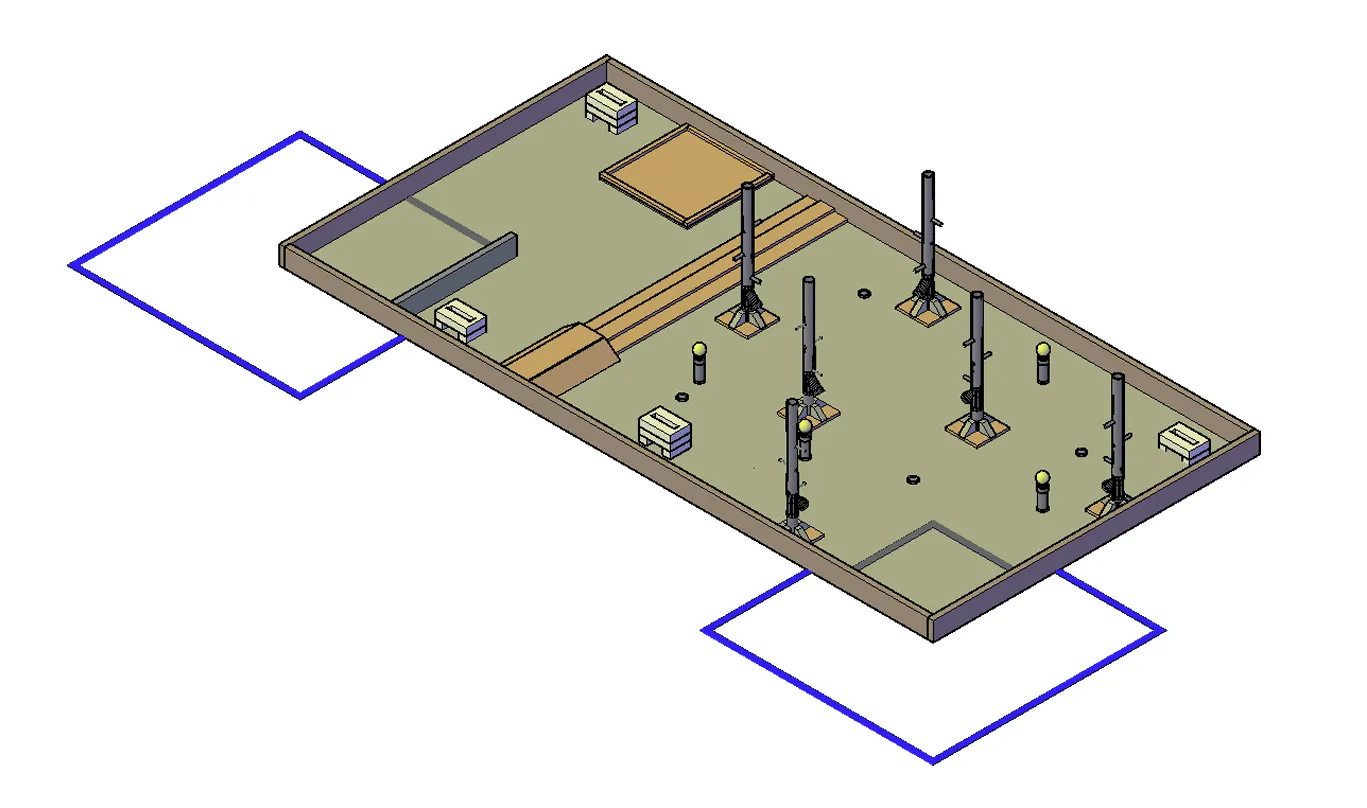
The goal of our robot was to collect sap (foam balls) from trees (PVC pipes) by pulling out dowels, bring them over to a boiler (wooden box) to turn the sap into taffy, then collect snow (foam blocks) and place the taffy on them to make maple syrup 😋. There were small saplings (tennis balls on PVC pipes) and rocks (bottle caps) we had to avoid, and cross over a bridge made of a few plywood planks.
We spent a lot of time in the planning phase, because it was easier to talk about doing something than actually doing it, we had quite a slow start, but it meant we had a lot of ideas of where we were going to go!
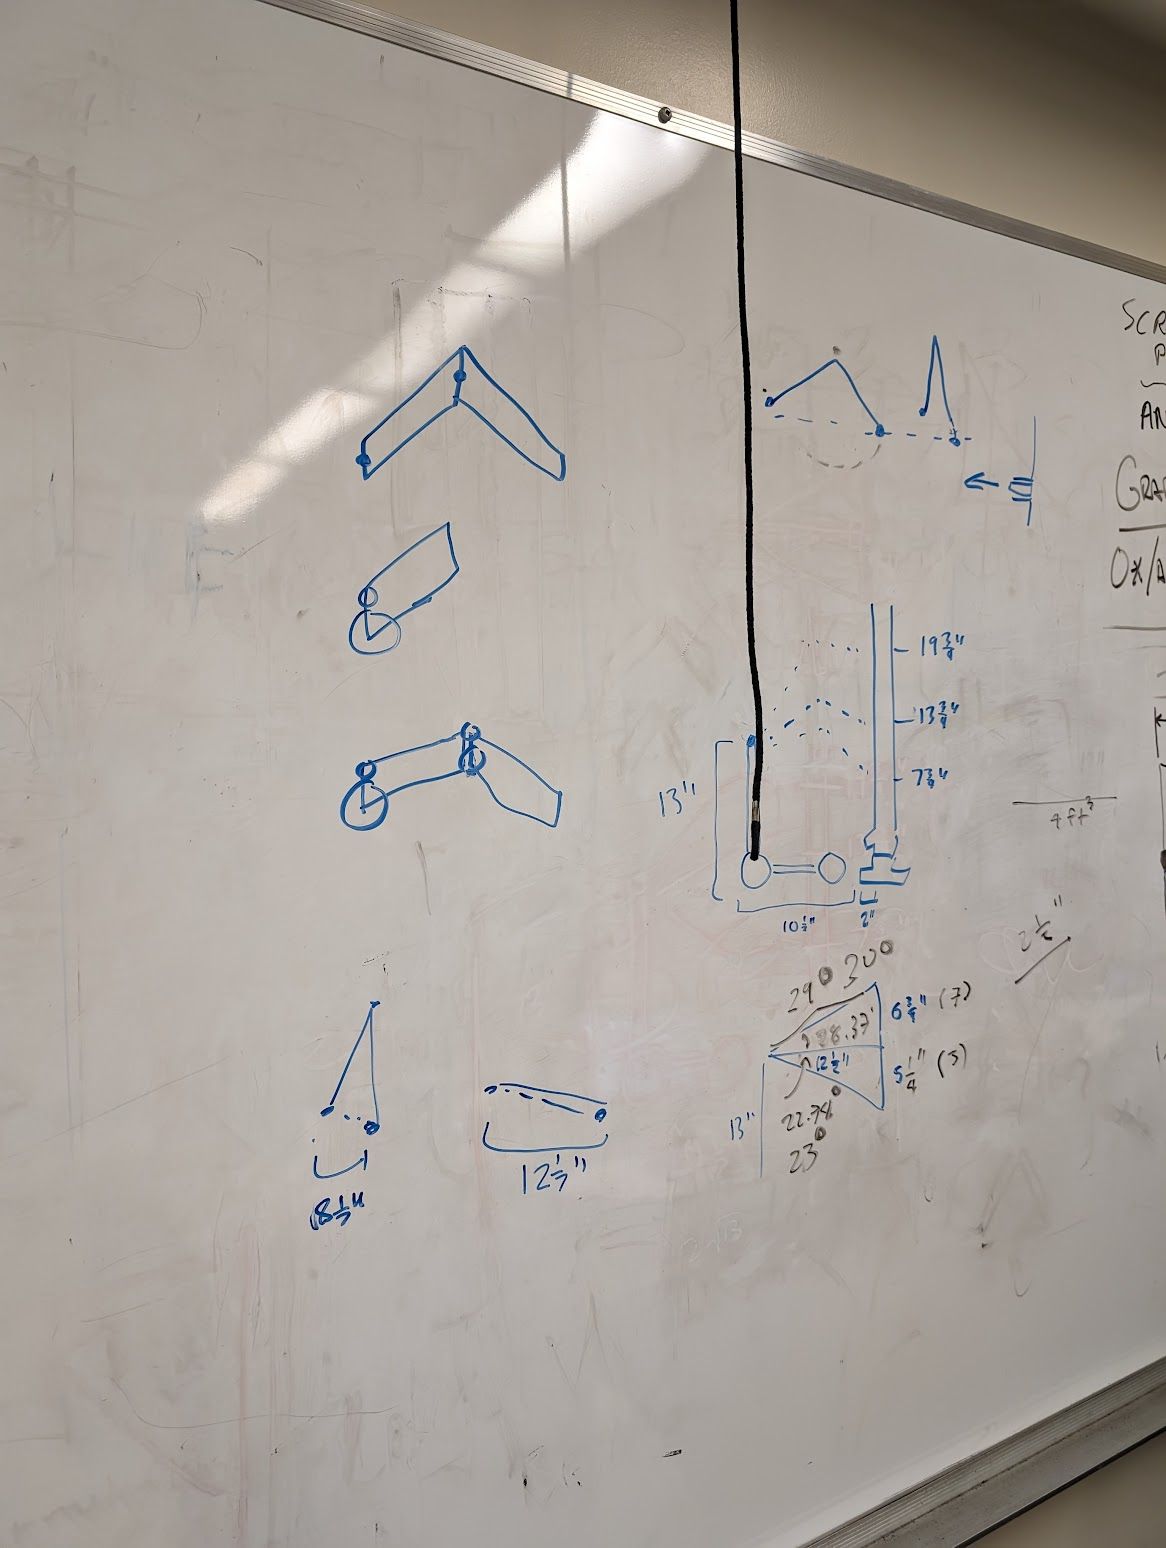
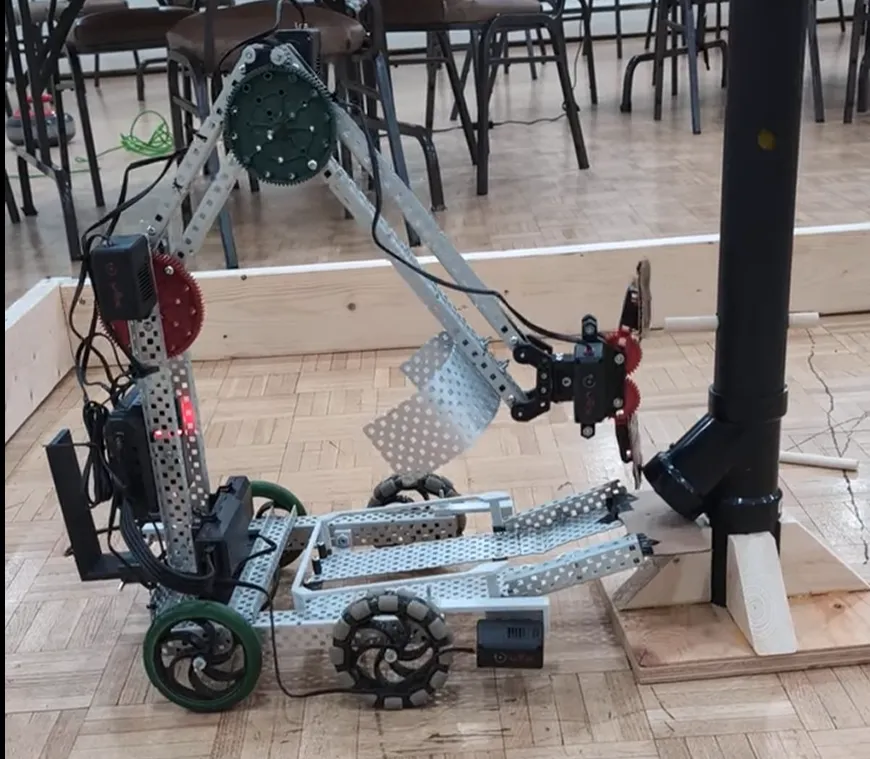
Our initial idea was to have two identical robots, each with an arm that could pull out the dowels from the trees to release the sap pieces, and a tray to collect the sap. They also each had a scoop to pick up the snow piles. The little bit of bent metal on the arm is to hold the balls from falling from the tray when going over the ramp!
We had a trial competition against another school in our school board, and from that we decided there were a few changes we wanted to make. We decided that having two identical robots worked in theory, but it would be better to optimize each for a specific task, as right now each one was mediocre at multiple jobs. We decided we would have one robot pull the top two dowels on the trees and then collect the snow piles, while another robot was dedicated to pulling the bottom dowel on the trees to release the sap pieces and bring them to the boiler.
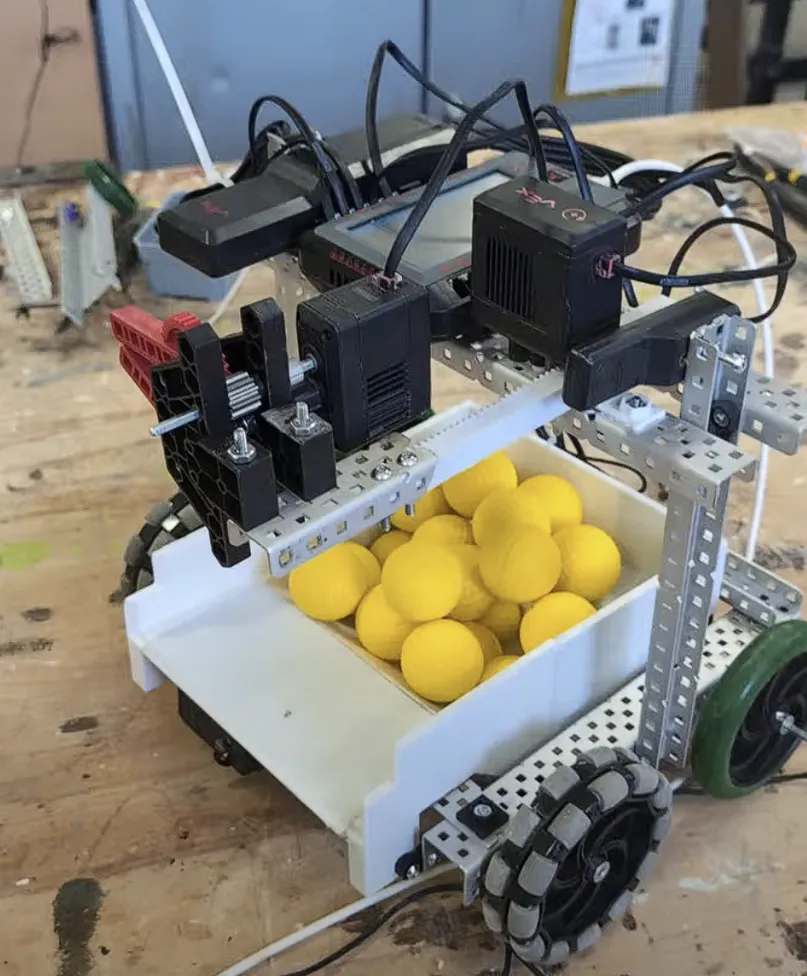
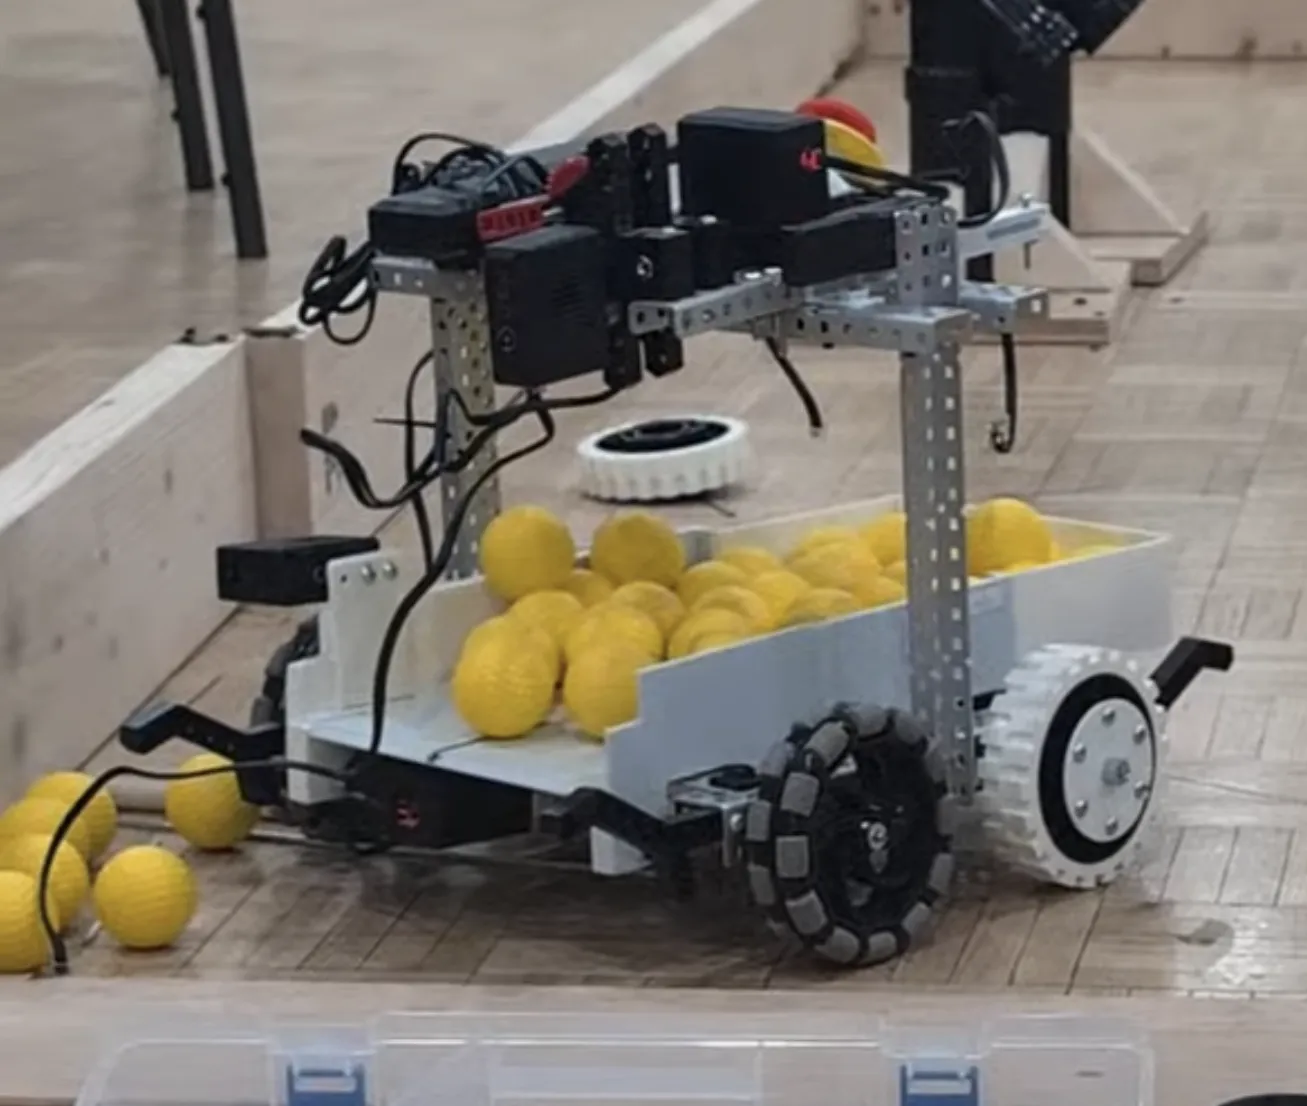
Here's the first of the two robots, with a massive tray designed to carry lots of the sap pieces. It uses a rack and pinion mechanism to move a claw towards the tree and to pull the bottom dowel, releasing the balls. It later also had a gate to keep the balls inside the tray while going over the ramp.
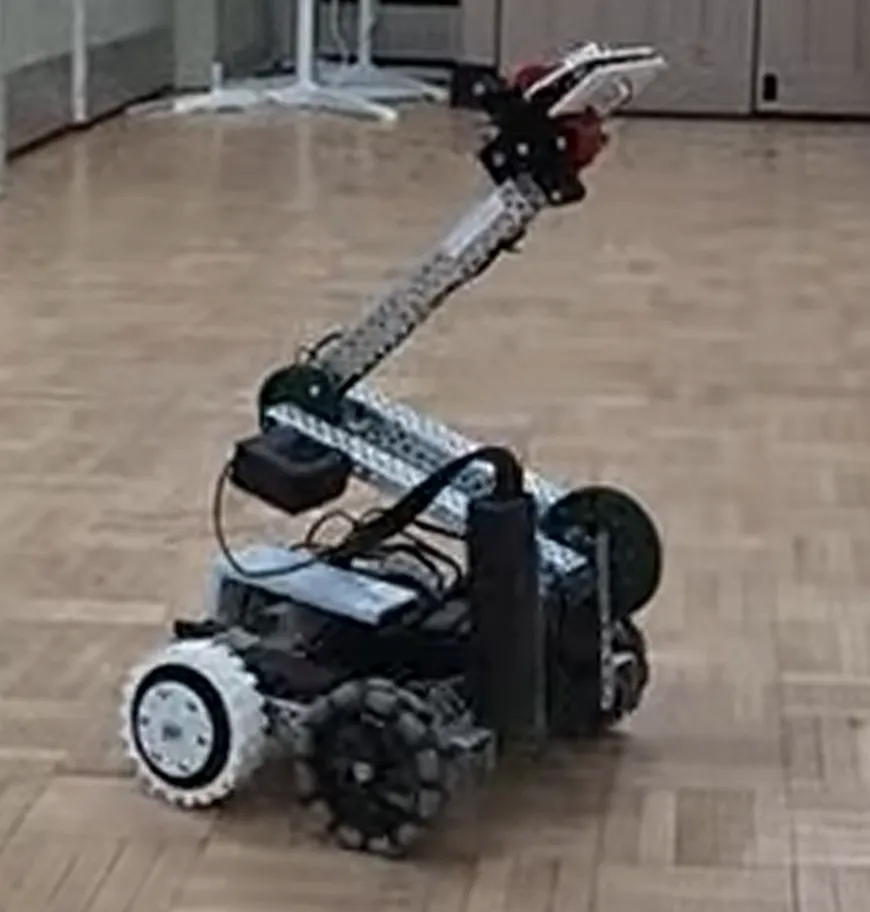
The second robot was a lot smaller, with a long arm to reach the top dowels, and a little lever on the back to scoop up the snow piles like a forklift!
By the time we had our robot design finalized, we did not have a lot of time before the start of the competition. We spent a good solid week after school every day until about midnight, and a bit the day before we left, working on our robots, testing them, and making sure we were all good to go!
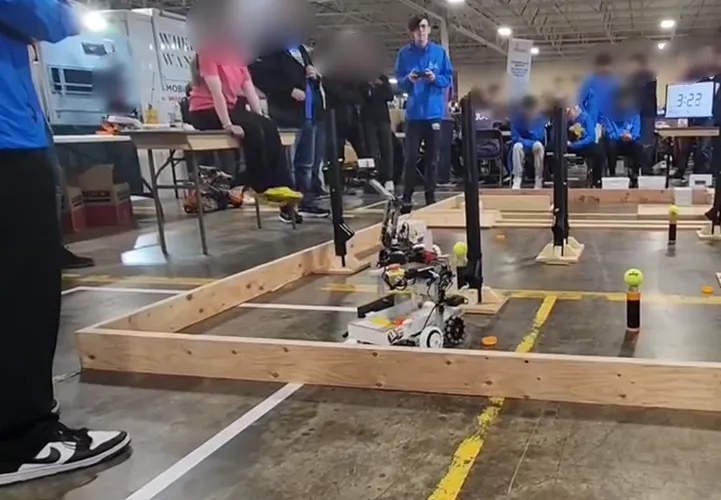
Actually competing in a game took a lot of team work, as there were very specific locations where the two drivers could stand, on either side of the arena, so neither driver had a great view of everything, especially when it came to lining up the robots with the trees or other obstacles. There's me in the background driving one of the robots!
We made it through the round robin, and in the playoffs we got 5th place! I'm really proud of everyone on my team who put in a lot of effort and stuck together to get this project done, I couldn't have asked for a better team. We did have a rough start and a few conflicts along the way, but everyone stuck together and we made it work. I'm really proud of how far we got in the competition, working on a limited budget and with no previous years of experience to help guide us.
Having this experience as a team leader was very meaningful to me, and it taught me a lot of skills I've used in the future when dealing with teams of people. I was able to introduce some new people into robotics, and teach them valuable skills in design and programming, which is really important to me!